OPEN LINK ↗
// 1h agoMODEL RELEASE
Manycore Tech open-sources UniPhysGen for robotic simulation
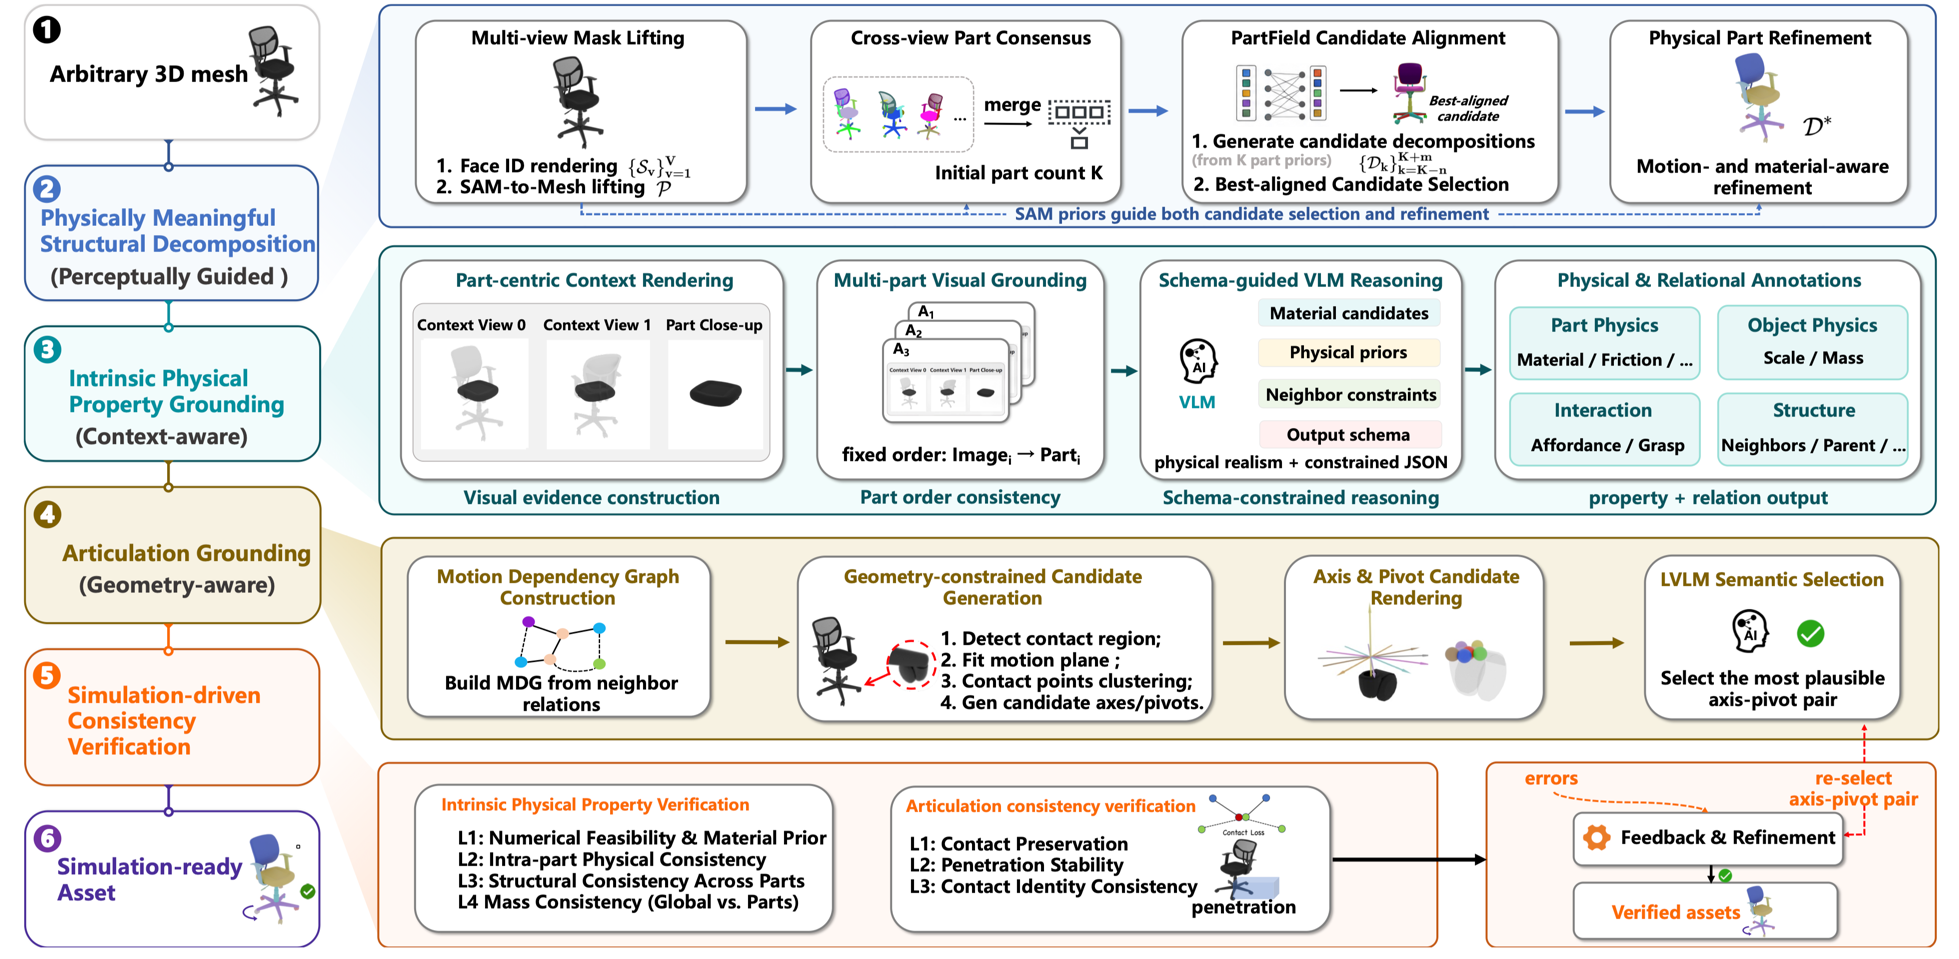
Manycore Tech, in partnership with Zhejiang University and UESTC, has open-sourced UniPhysGen, a physical AI model that converts raw 3D assets into interactive, simulation-ready digital twins by predicting articulation kinematics and physical properties. Alongside model weights and code, the team released the UniPhys-40K dataset and UniPhys-Bench evaluation benchmark to advance embodied AI research.
// ANALYSIS
Transforming static 3D meshes into physically reactive objects has been one of the biggest bottlenecks in robotics training, and UniPhysGen automates this physical grounding process at scale.
- –Bridges the simulation gap: Converts static 3D digital assets into interactive objects equipped with joints, motion limits, and physical dynamics ready for simulation engines.
- –Geometry-robust grounding: Accurately infers articulation semantics and motion axes across heterogeneous part decompositions without needing strict canonical alignments.
- –Comprehensive open ecosystem: Releasing weights, code, the UniPhys-40K dataset, and UniPhys-Bench gives researchers a complete toolkit for physical AI data generation.
- –Accelerates synthetic data generation: Enables scalable creation of interactive virtual training environments to train robot manipulation and navigation policies.
// TAGS
physical-aiembodied-airobotics3d-assetssimulationopen-sourcellmmanycore-tech
DISCOVERED
1h ago
2026-09-17
PUBLISHED
1h ago
2026-09-17
RELEVANCE
8/ 10
AUTHOR
ManycoreTech