OPEN LINK ↗
// 1h agoBENCHMARK RESULT
Tactile FLORA Wins Hackathon Silver
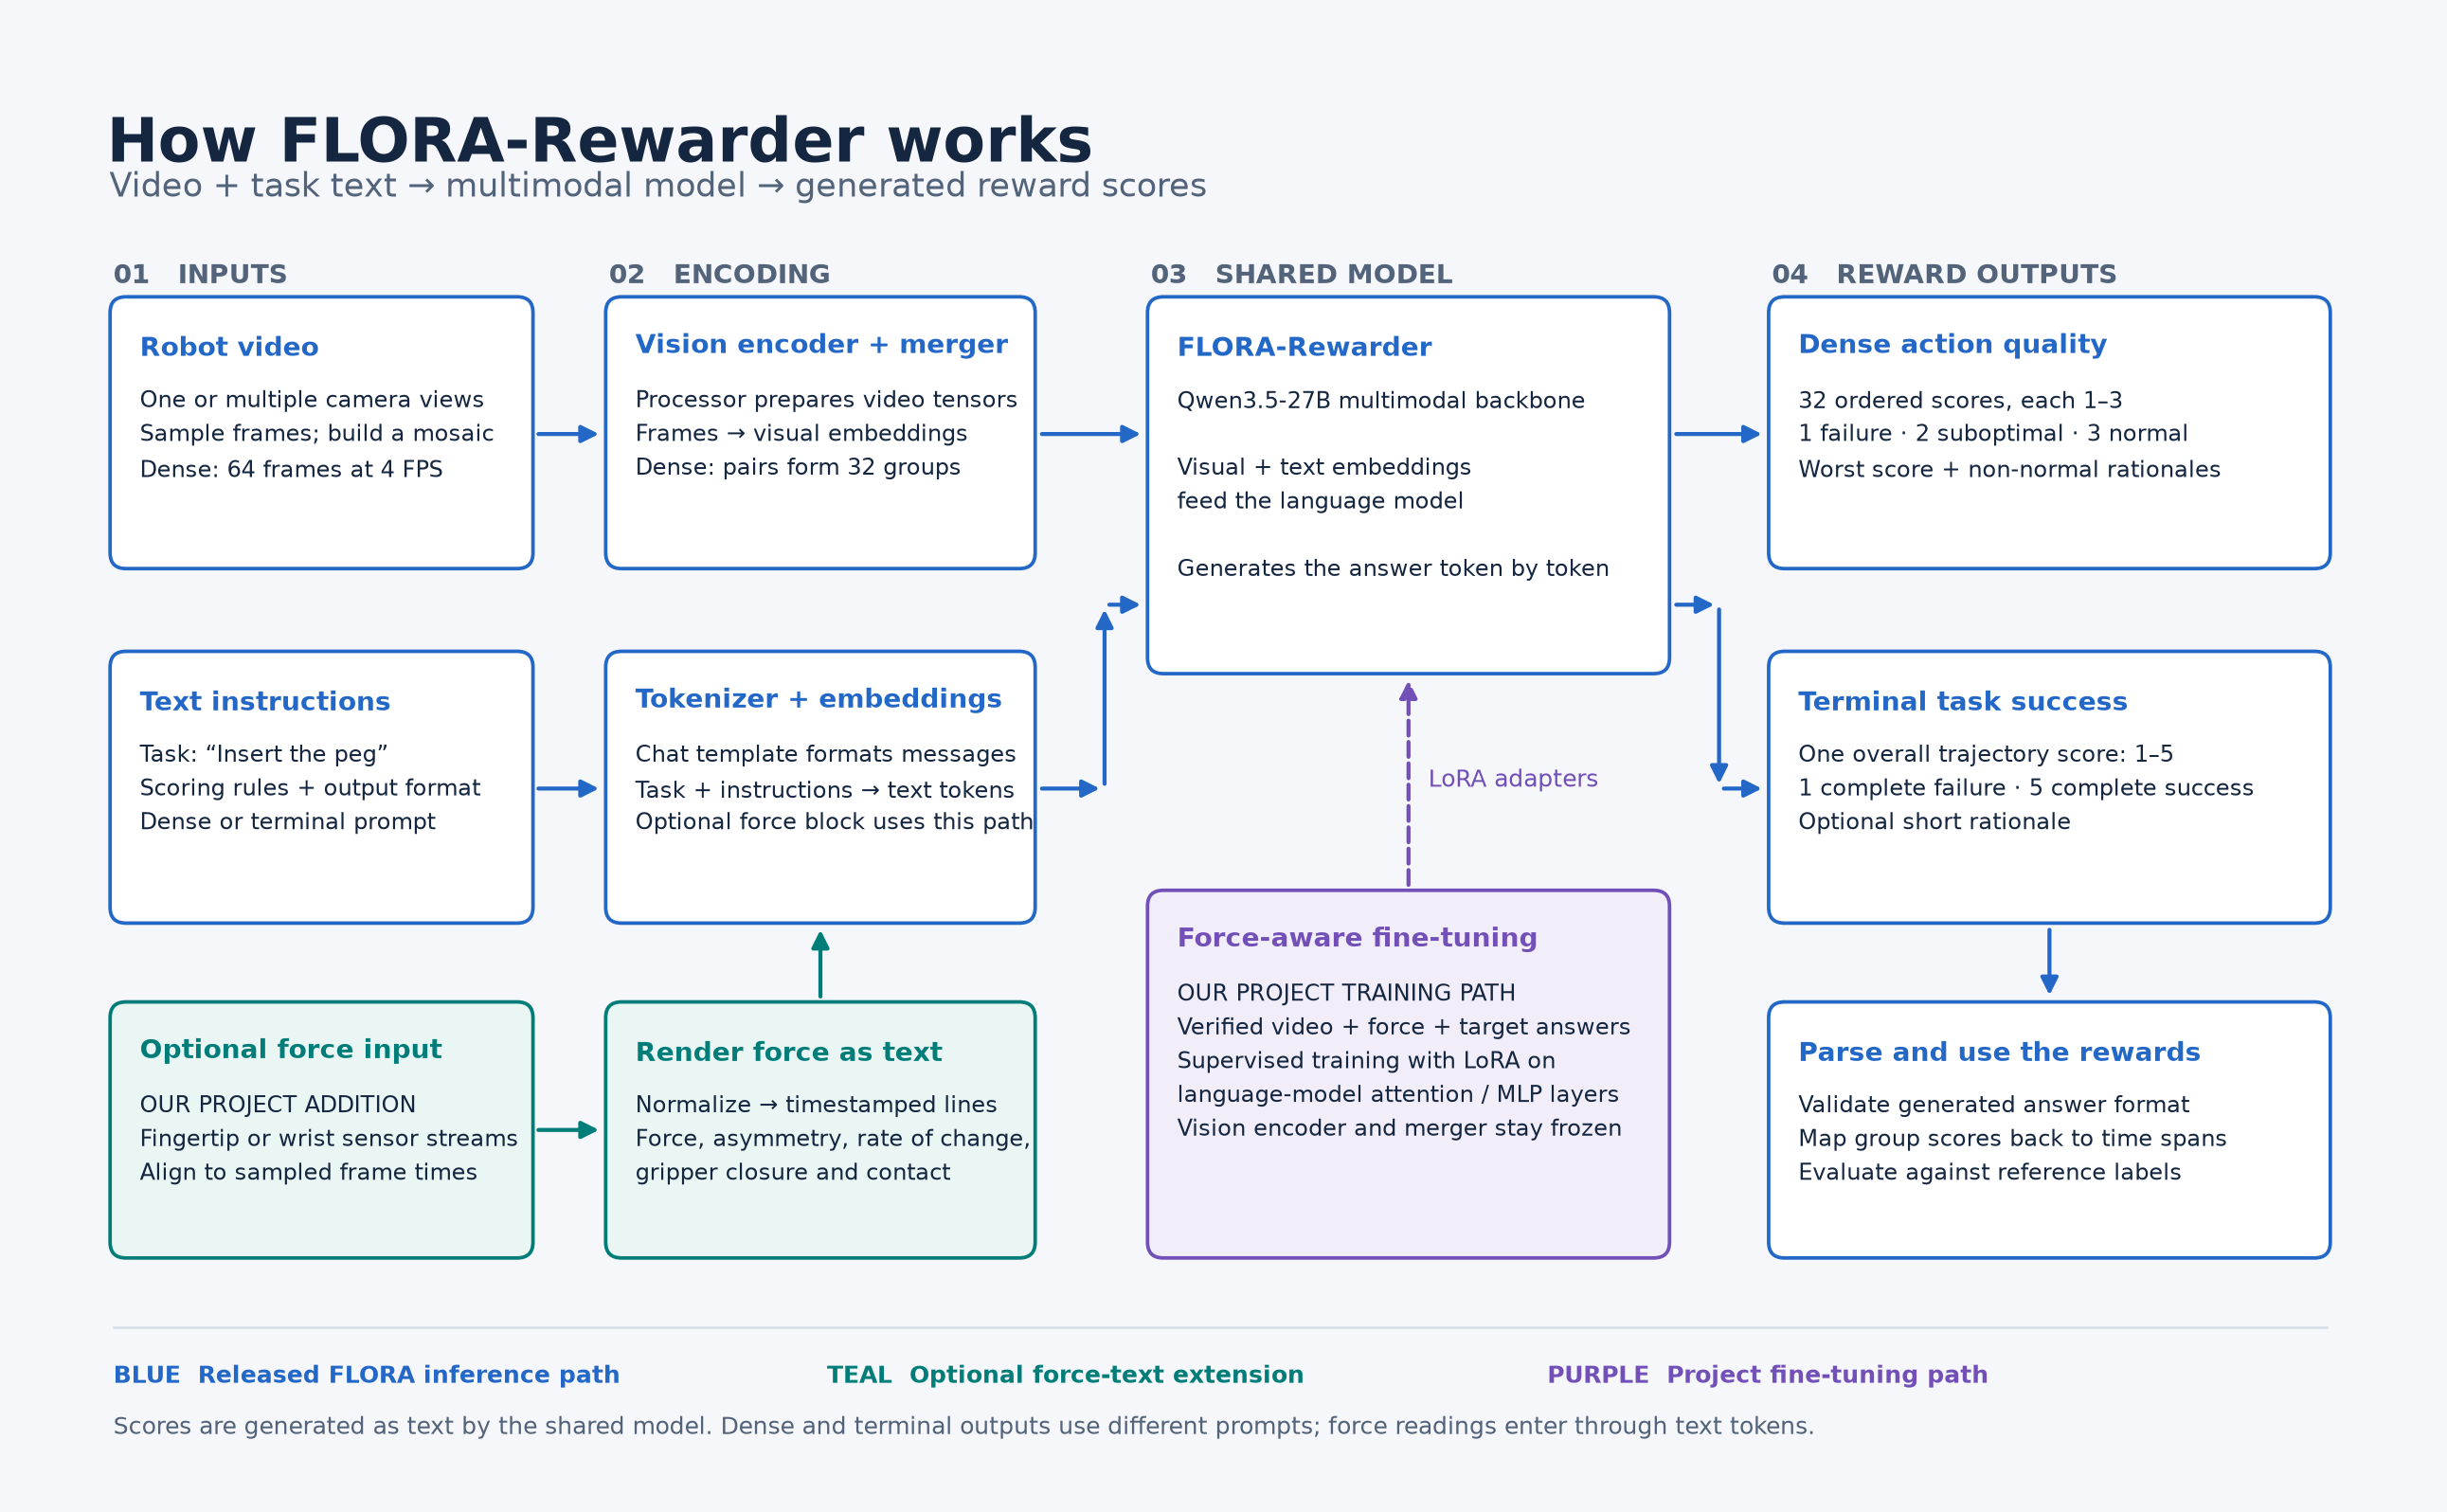
A fine-tuned, tactile-aware FLORA supervisor earned second place at Junfan Labs Robotics Hackathon #35. The project applies FLORA’s robotics data-labeling and reward-modeling approach to contact-rich robot behavior.
// ANALYSIS
Tactile supervision could become a key bridge between impressive robot demos and dependable manipulation.
- –Touch signals expose failures that vision-only systems miss, especially during grasping and insertion.
- –Fine-tuning a reward supervisor offers a practical path to improve robot policies without redesigning the entire control stack.
- –NVIDIA positions FLORA for process rewards, outcome scoring, and dataset curation—not direct robot control or sole safety monitoring.
- –The project highlights hackathons as useful proving grounds for fast, embodied-AI experimentation.
- –The biggest open question is generalization: whether tactile supervision transfers across sensors, robots, objects, and tasks.
// TAGS
tactile-florafloraroboticsfine-tuningtrainingevaluationsafety
DISCOVERED
1h ago
2026-10-25
PUBLISHED
1h ago
2026-10-25
RELEVANCE
8/ 10
AUTHOR
junfanzhu98